
Every function becomes an actuator
Steering, transmission, hydraulics and brakes need controlled, deterministic actuation over CAN.
Taking the operator out of the cab does not remove the steering, the hydraulics or the brakes — it moves them onto the bus. Makersan supplies the drive-by-wire control, the position and angle sensing and the telemetry that an autonomous machine runs on, and the supervisor's display for the people who now watch it from elsewhere.
Steering, transmission, hydraulics and brakes need controlled, deterministic actuation over CAN.
Independent paths and defined defaults bring the machine to a stop when a link or a module drops.
Angle, inertial and position sensing give the autonomy stack measurement it can trust.
Onboard logging and telemetry record what the machine did, for tuning and for the safety case.
Machine-qualified modules that take a command from the stack and move real hydraulics.
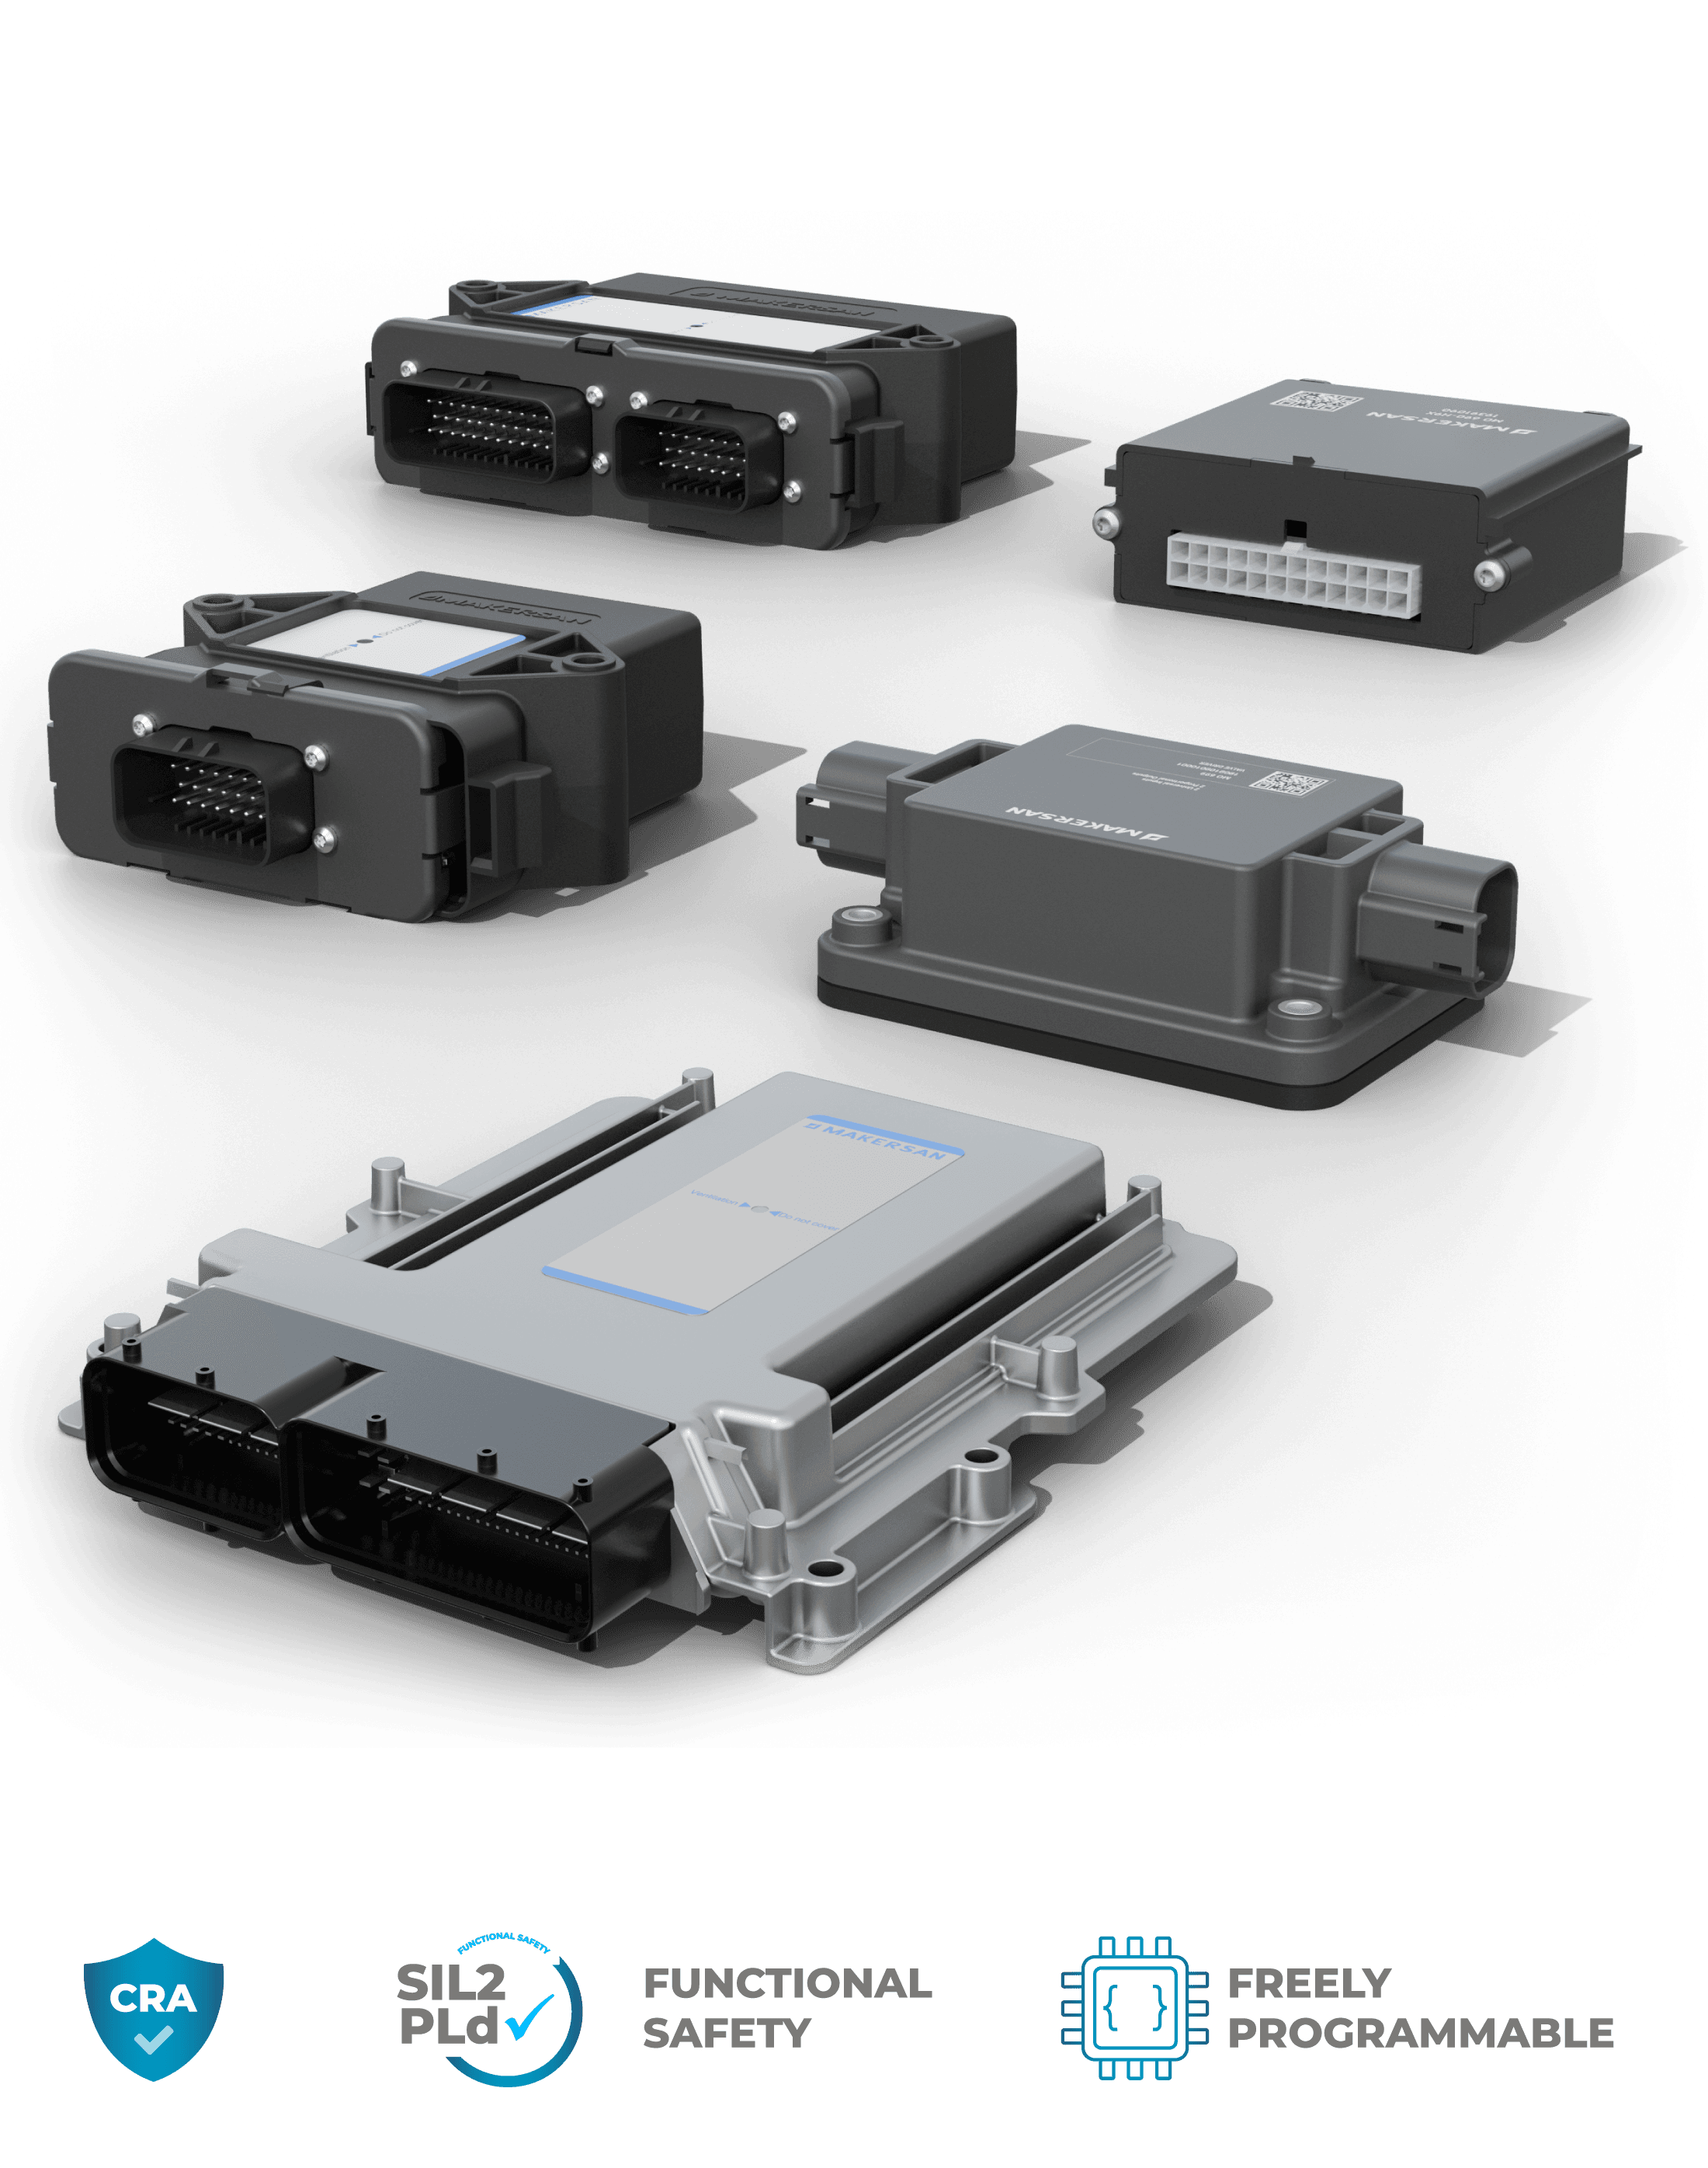
Drive-by-wire control of valves, motors and machine functions.
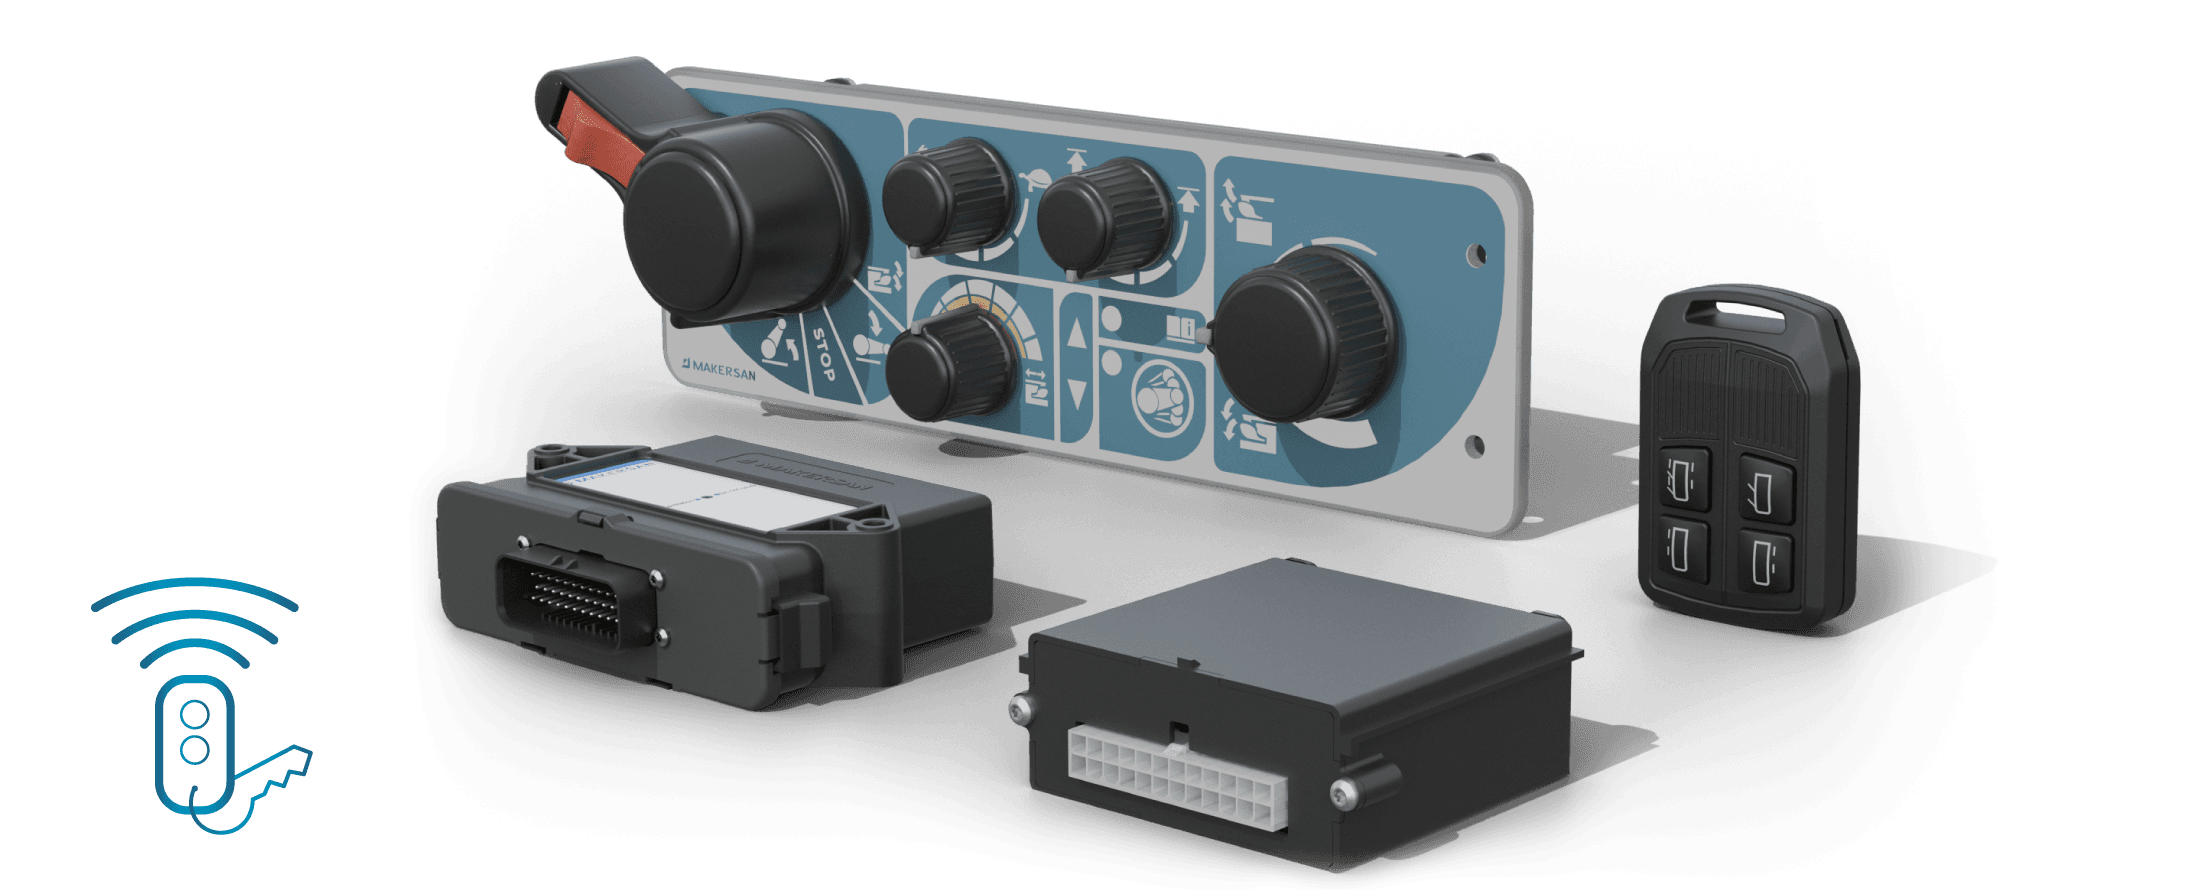
Purpose-built modules for steering, transmission and brake interfaces.
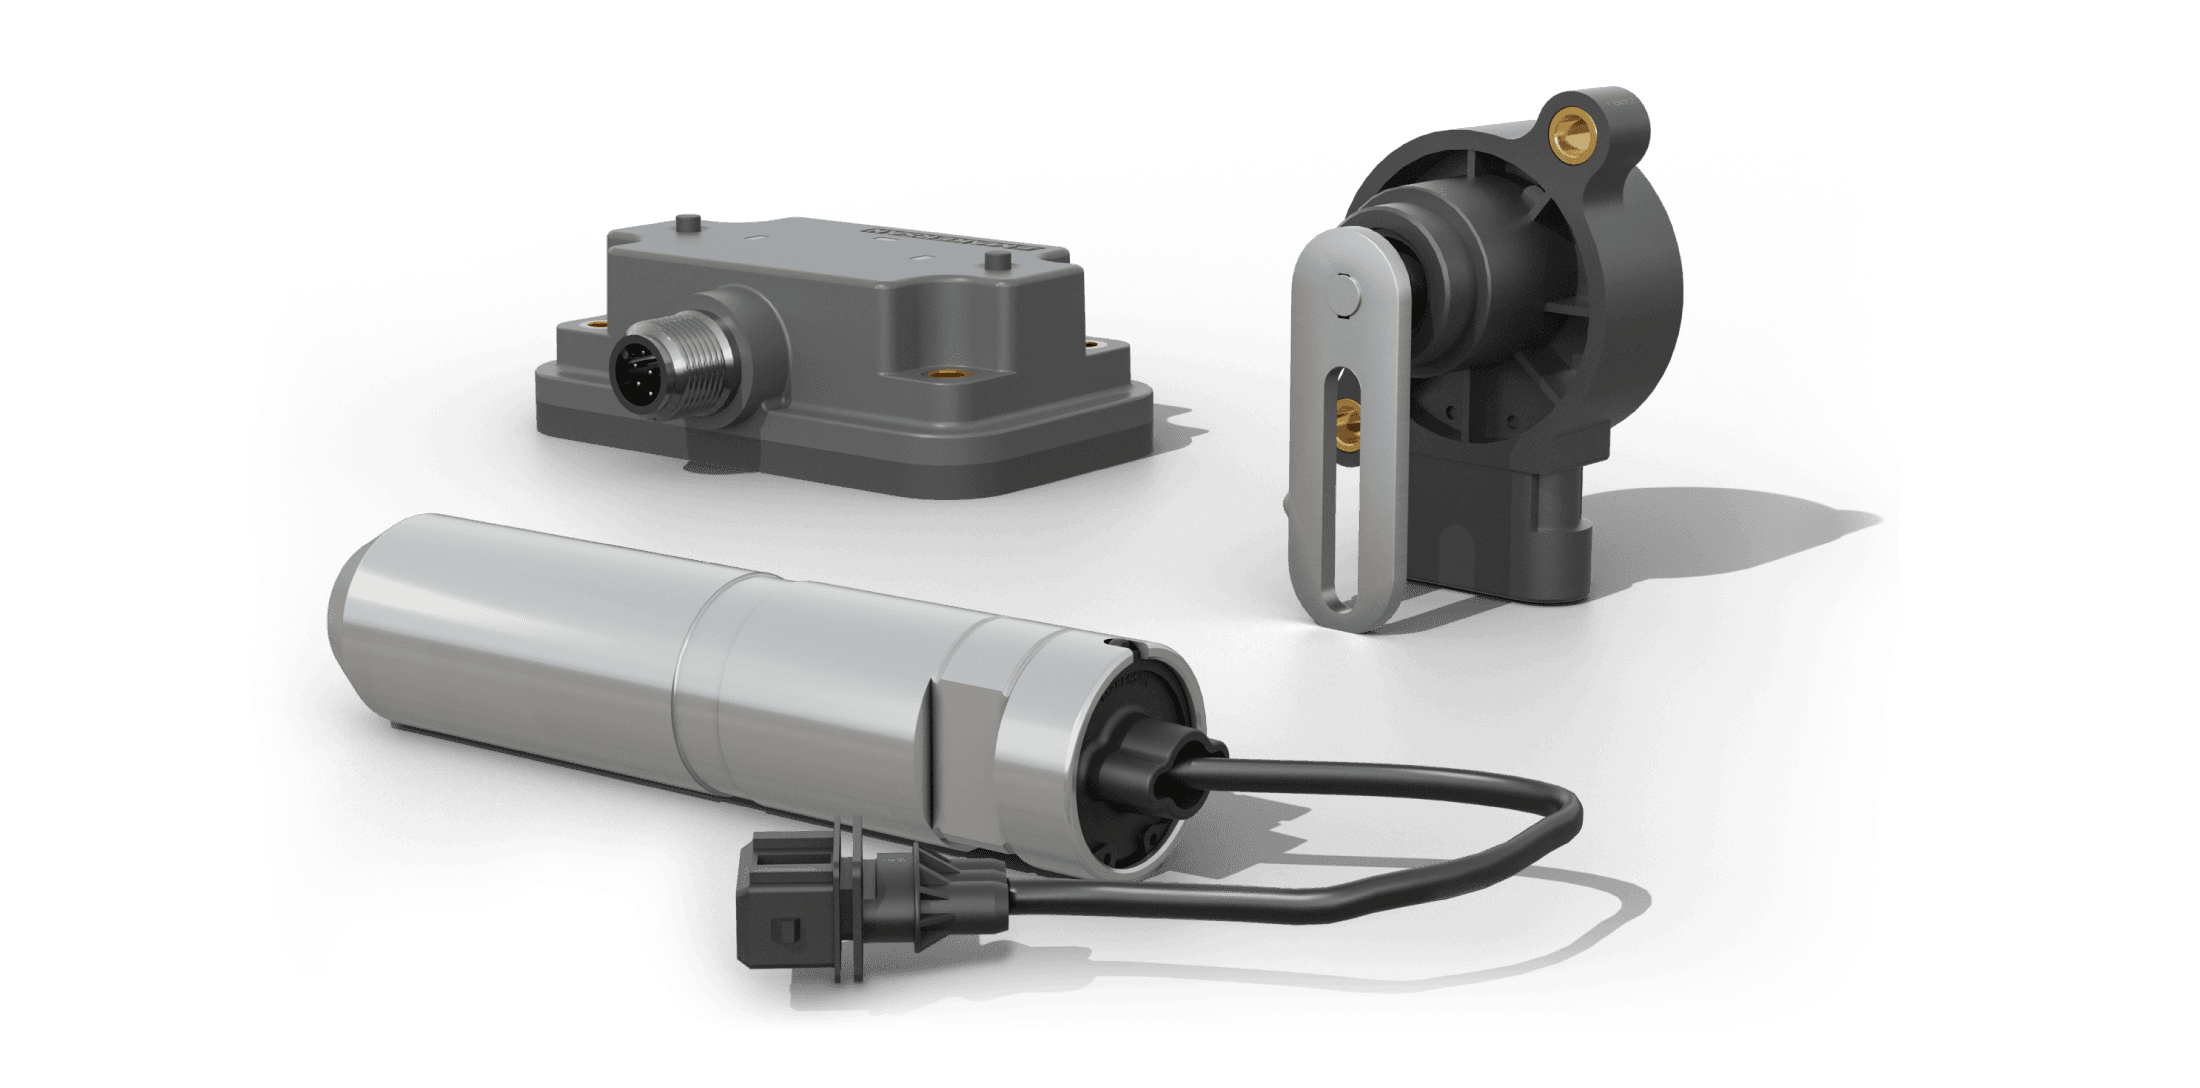
Angle, inertial, pressure and position sensing for the autonomy stack.
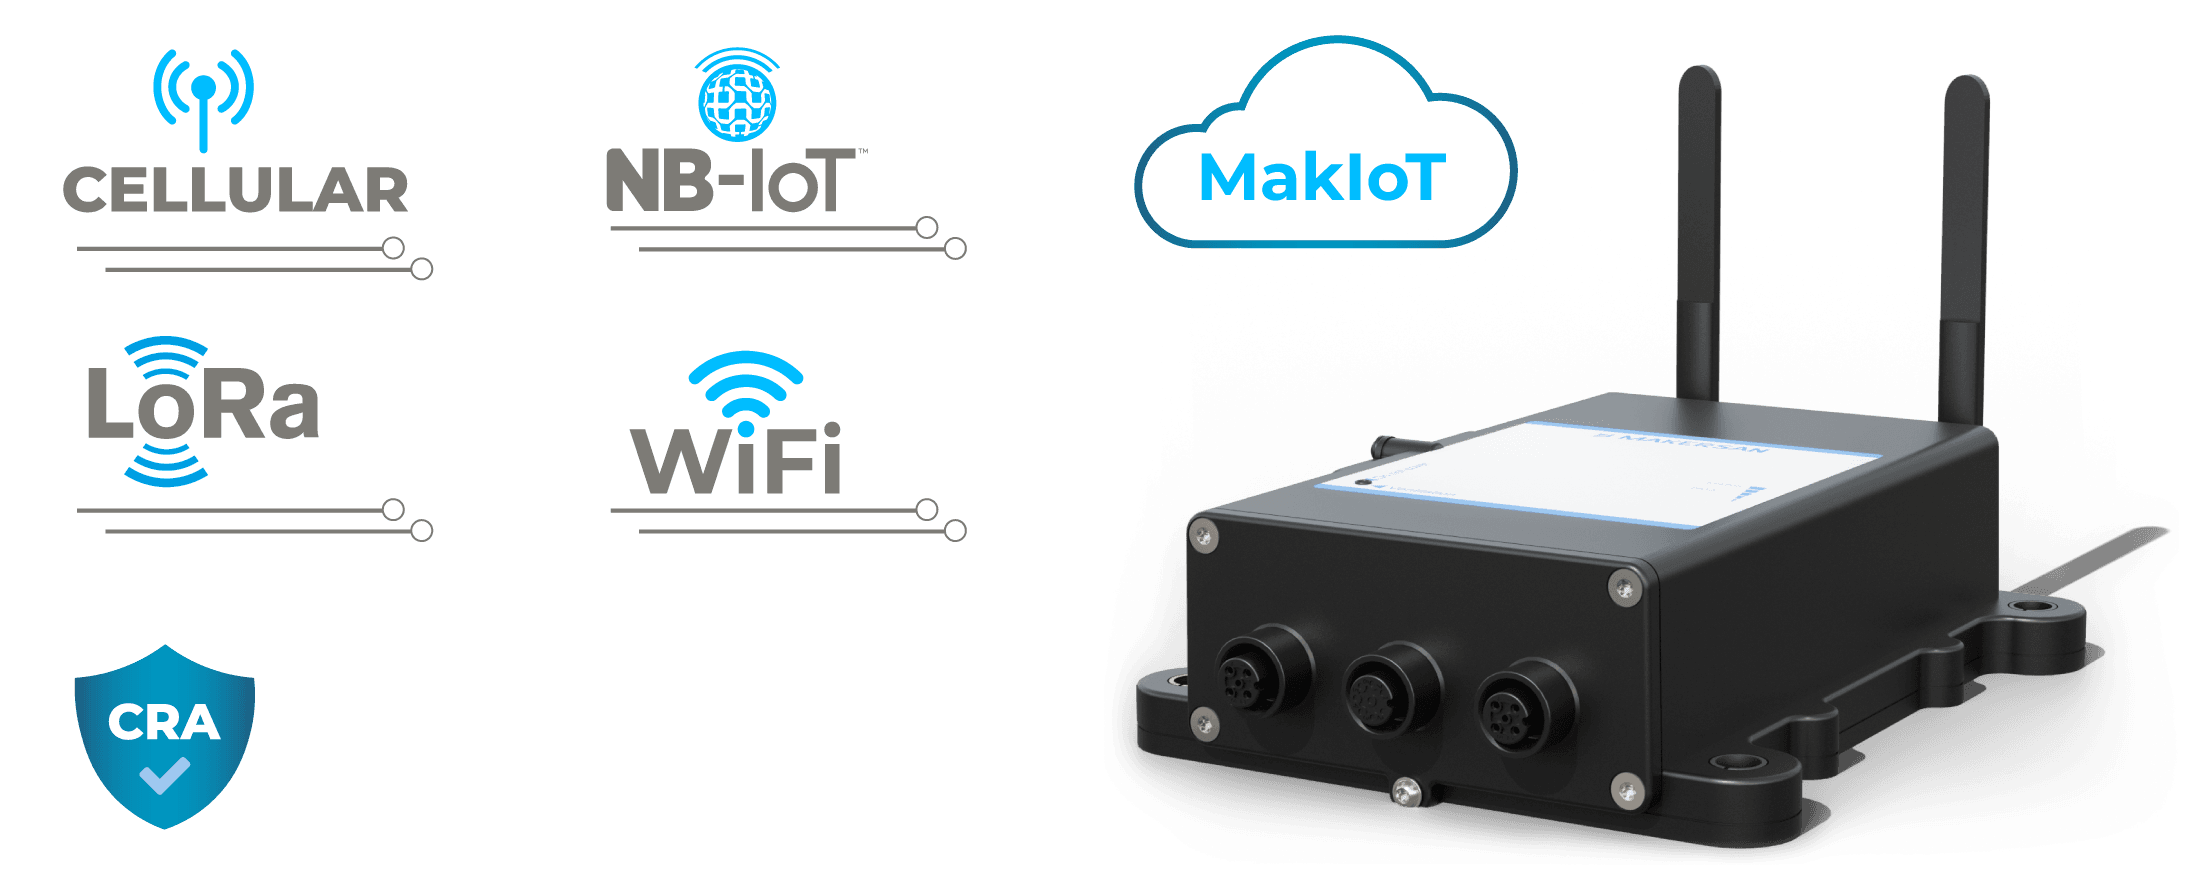
Telemetry, remote supervision and over-the-air updates.
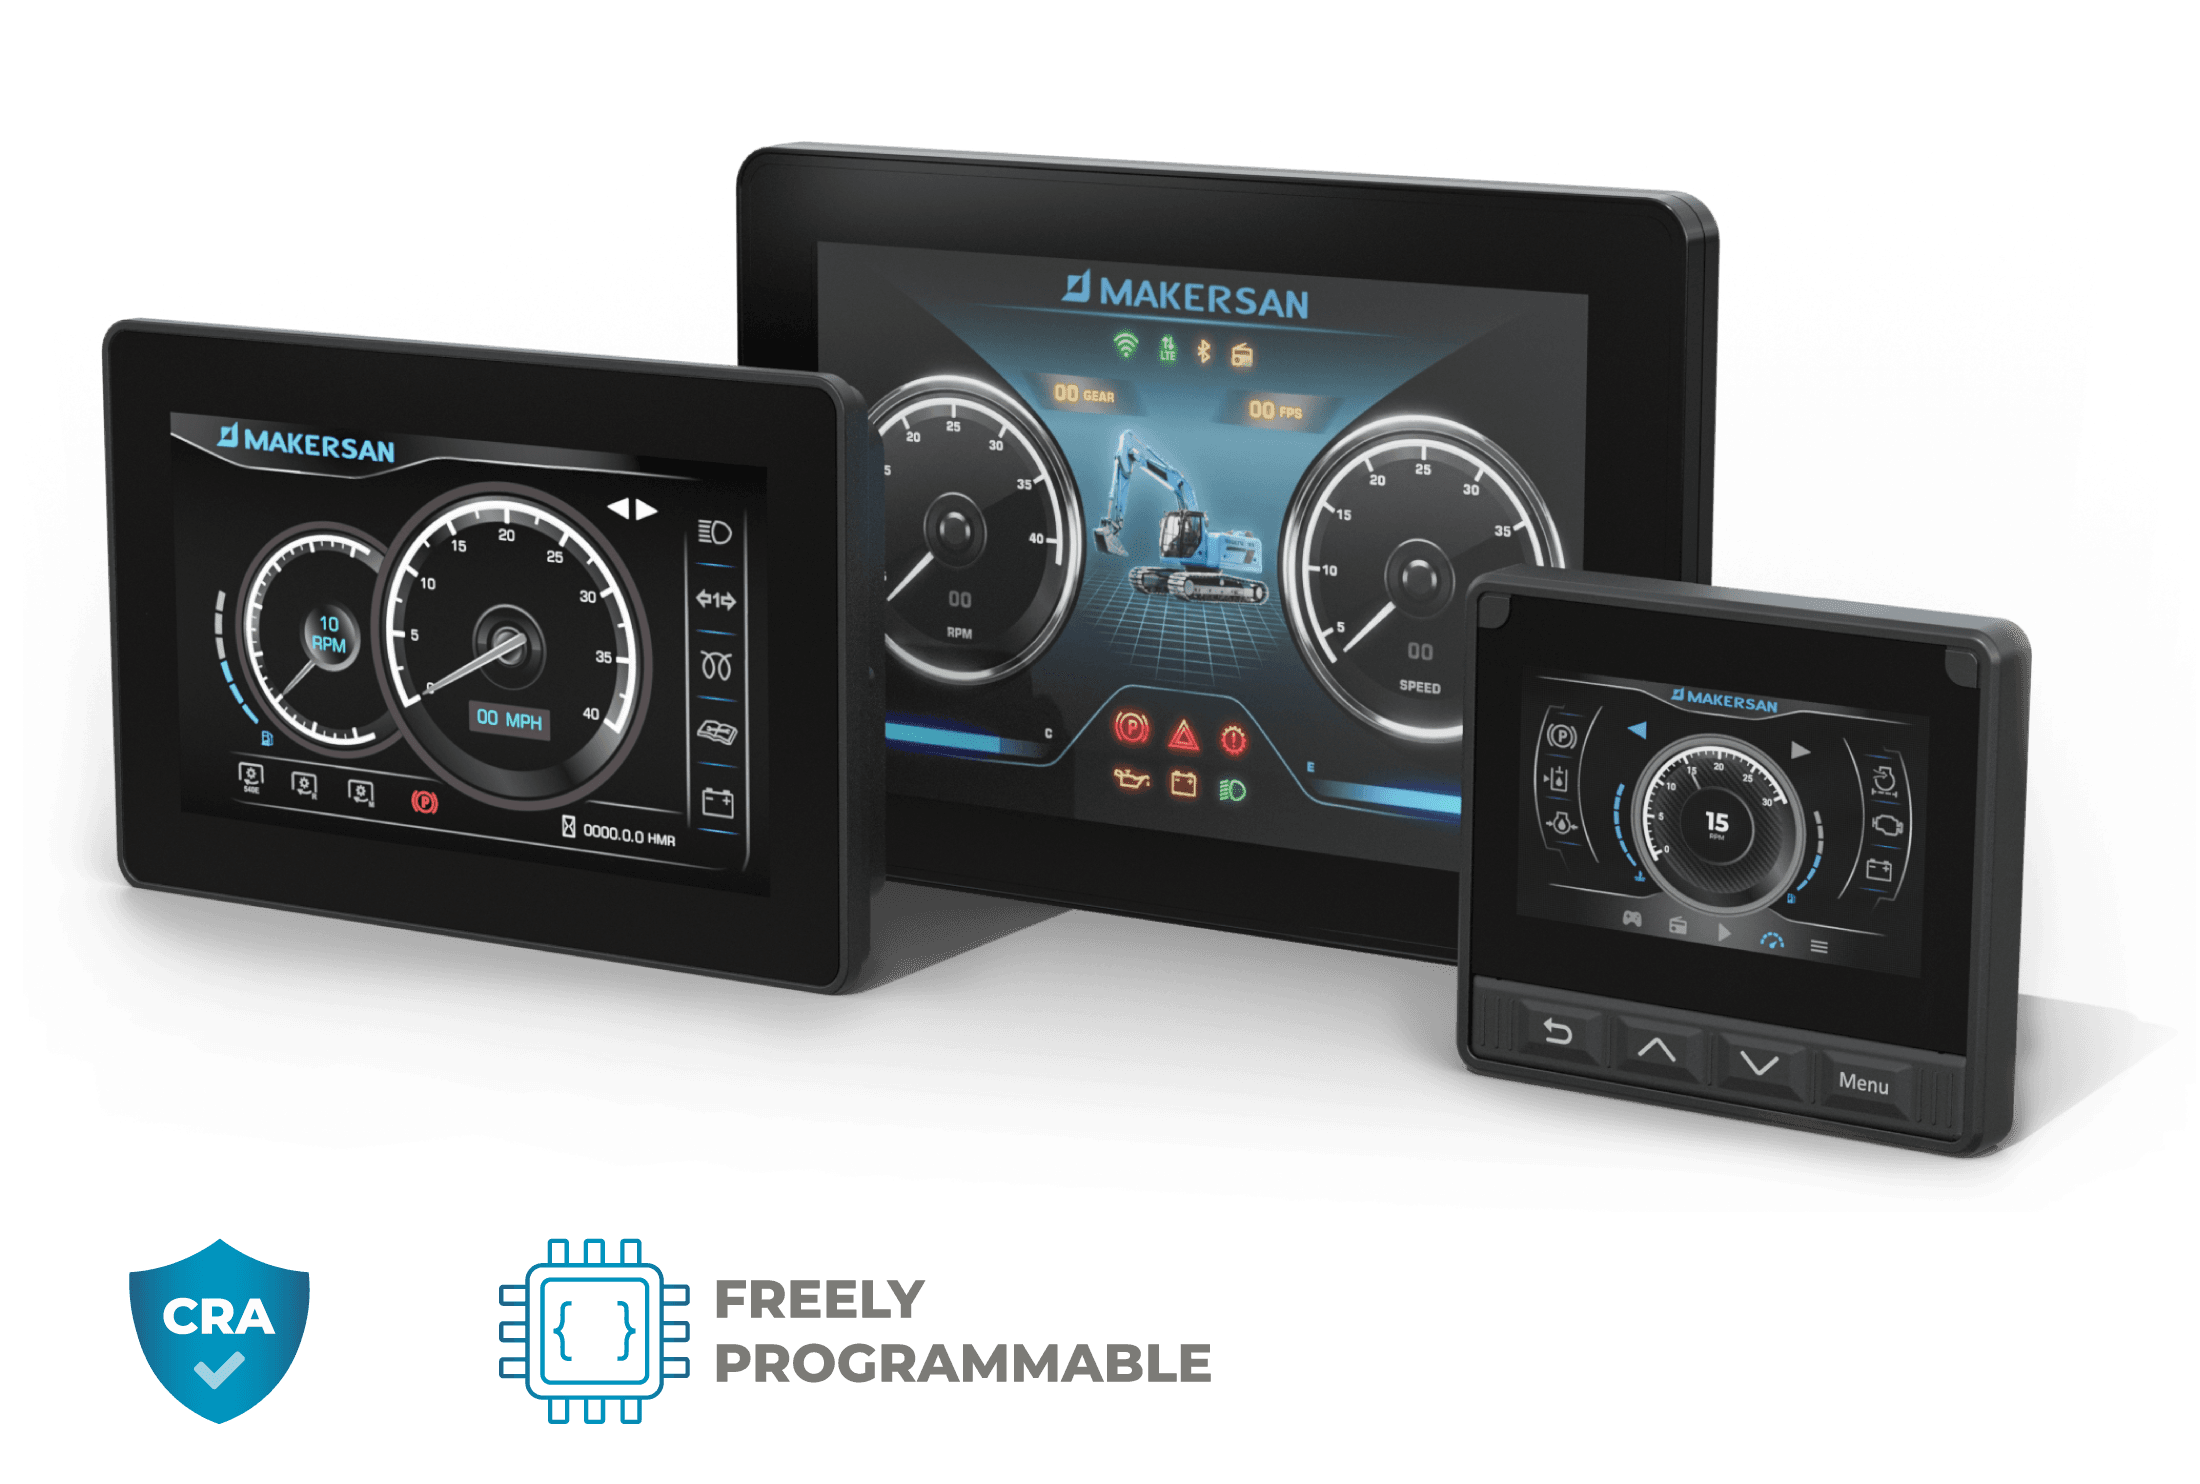
Supervisor and cab displays for machines that still carry a seat.
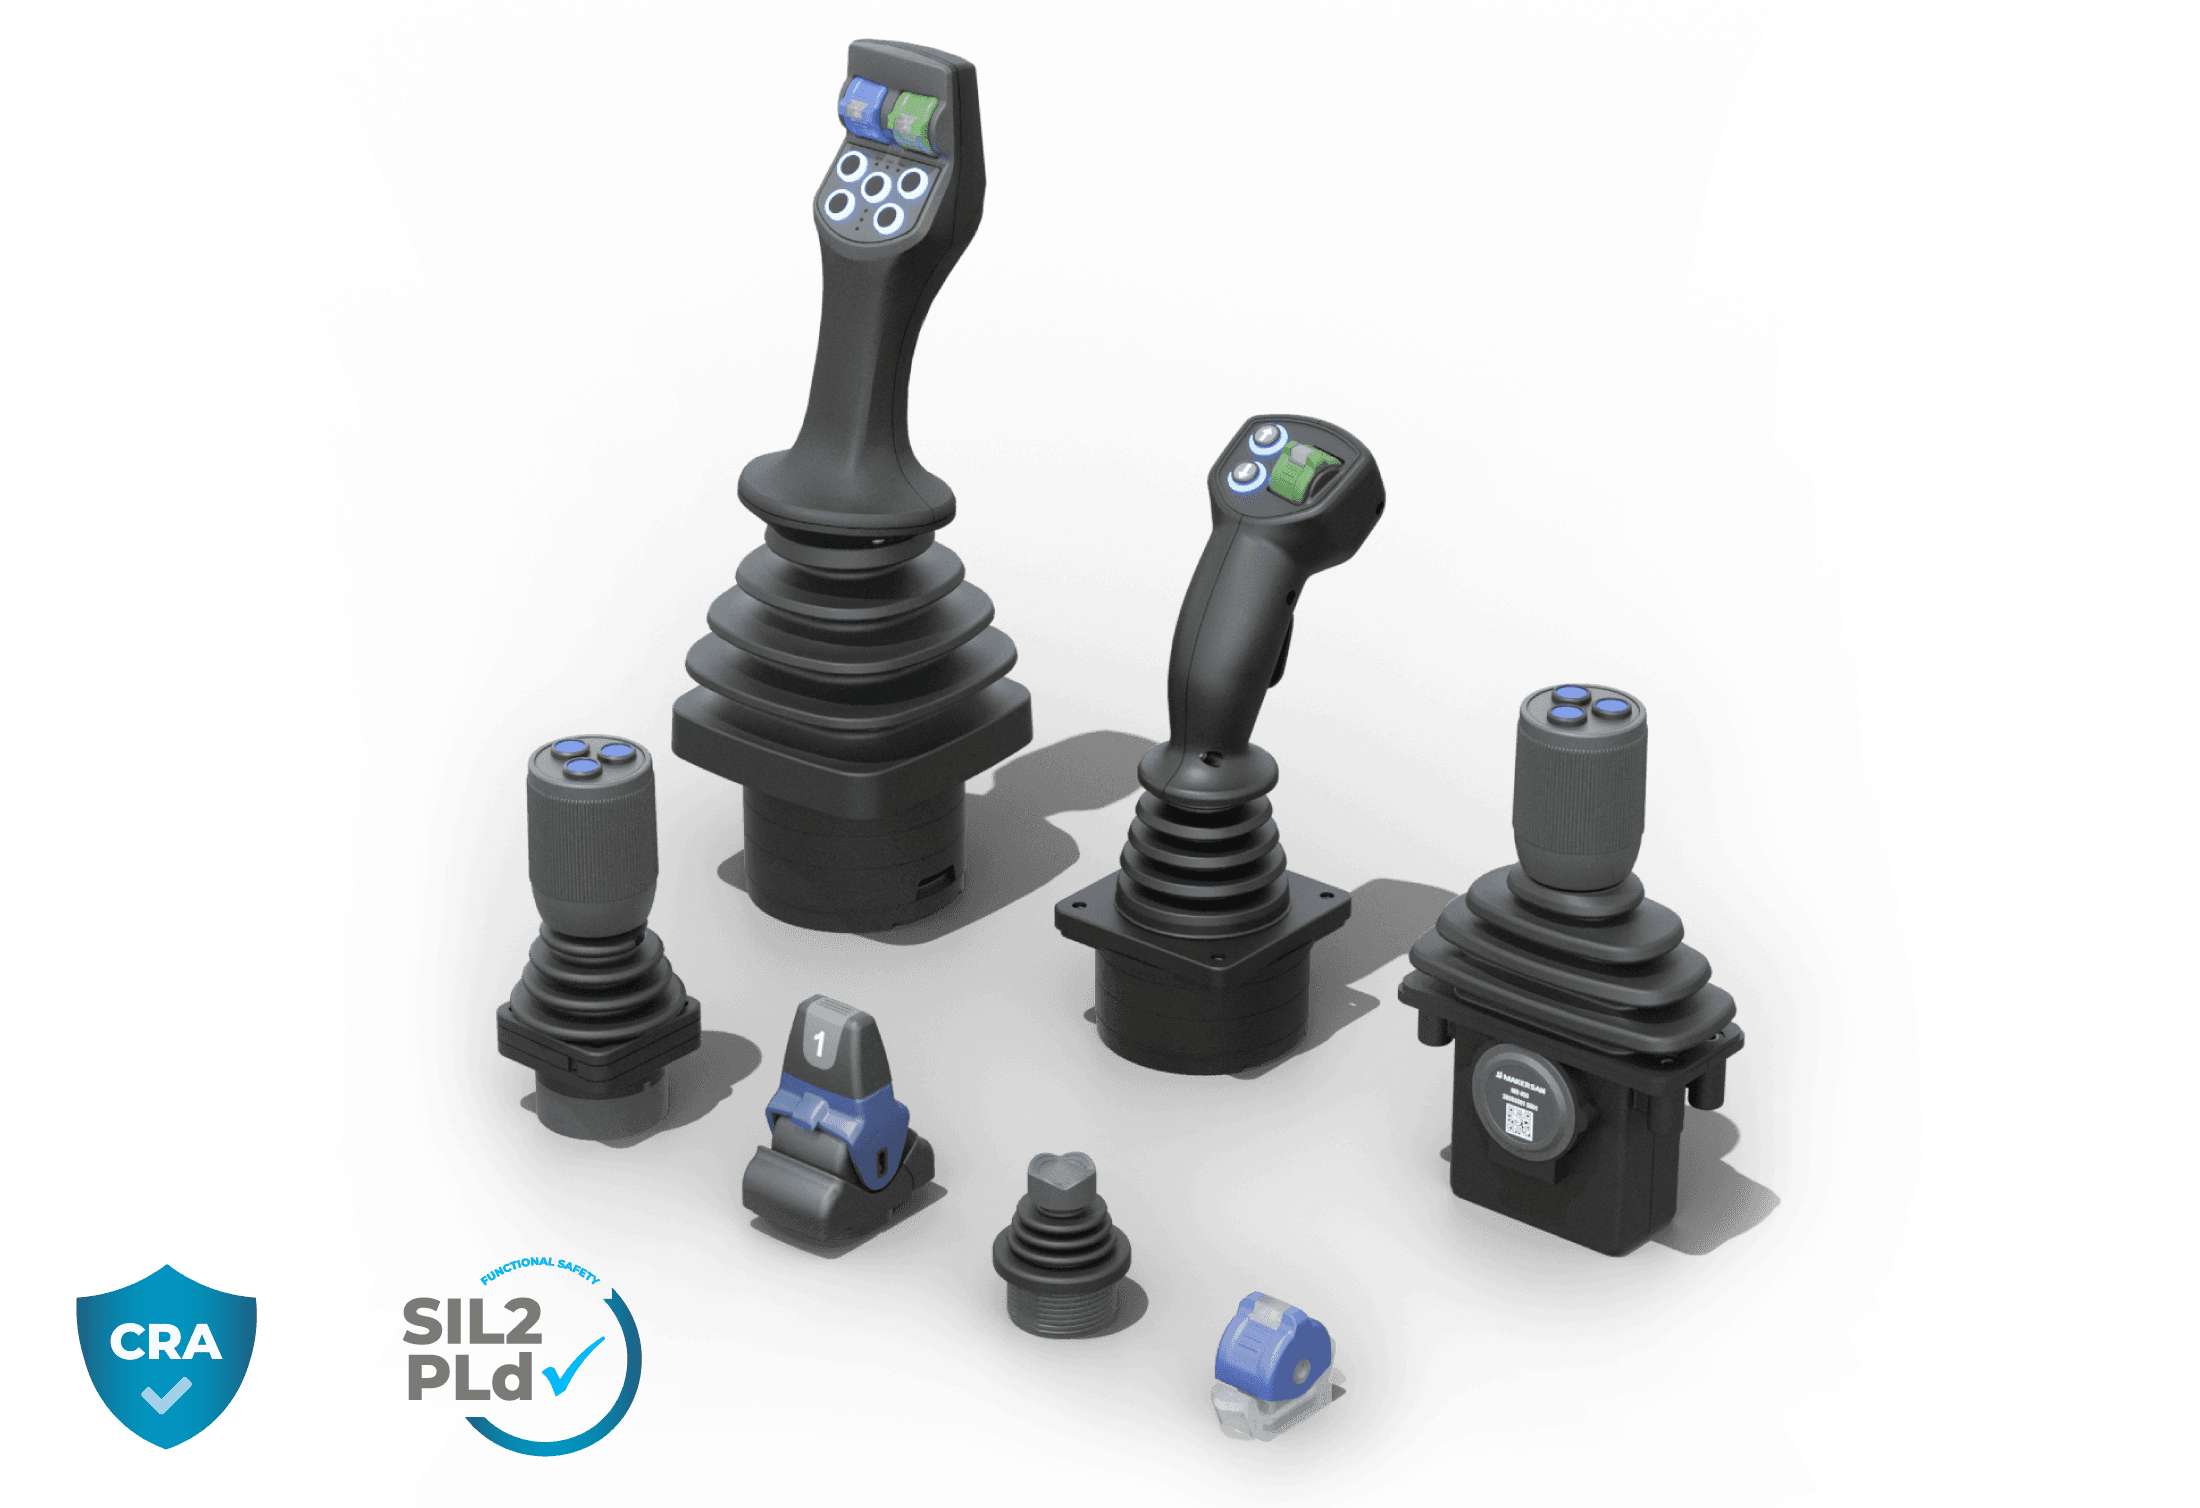
Joysticks for teleoperation and manual recovery.
The same sealing, temperature and EMC programme as our off-highway line, with the deterministic bus behaviour an autonomy stack depends on.
Send us the machine's function list and the interface your stack expects, and our engineers will spec the control, sensing and telemetry between them.